Projects
Research and engineering work in robotics, dynamics, control, and robotic systems.
Each project page separates the method, my role, and the available evidence so that simulation, cross-simulator checks, and hardware results remain distinct.
01
Research
5 projects
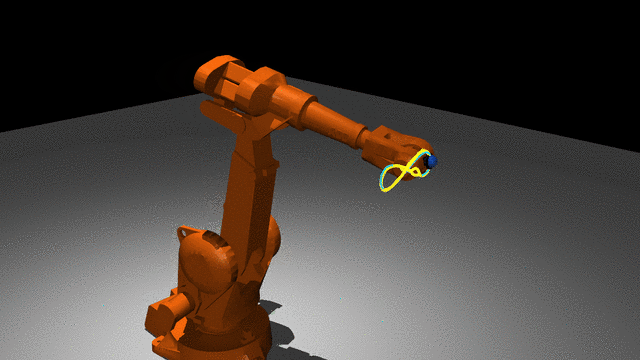
Activation-Aligned Residual MPC for Robot Manipulators
An actuator-aware residual MPC system evaluated in ABB and UR5e MuJoCo simulations and, under a separate hardware protocol, on SO-ARM101.
- Model Predictive Control
- Learned Dynamics
- GRU
- MuJoCo
- Robot Manipulation
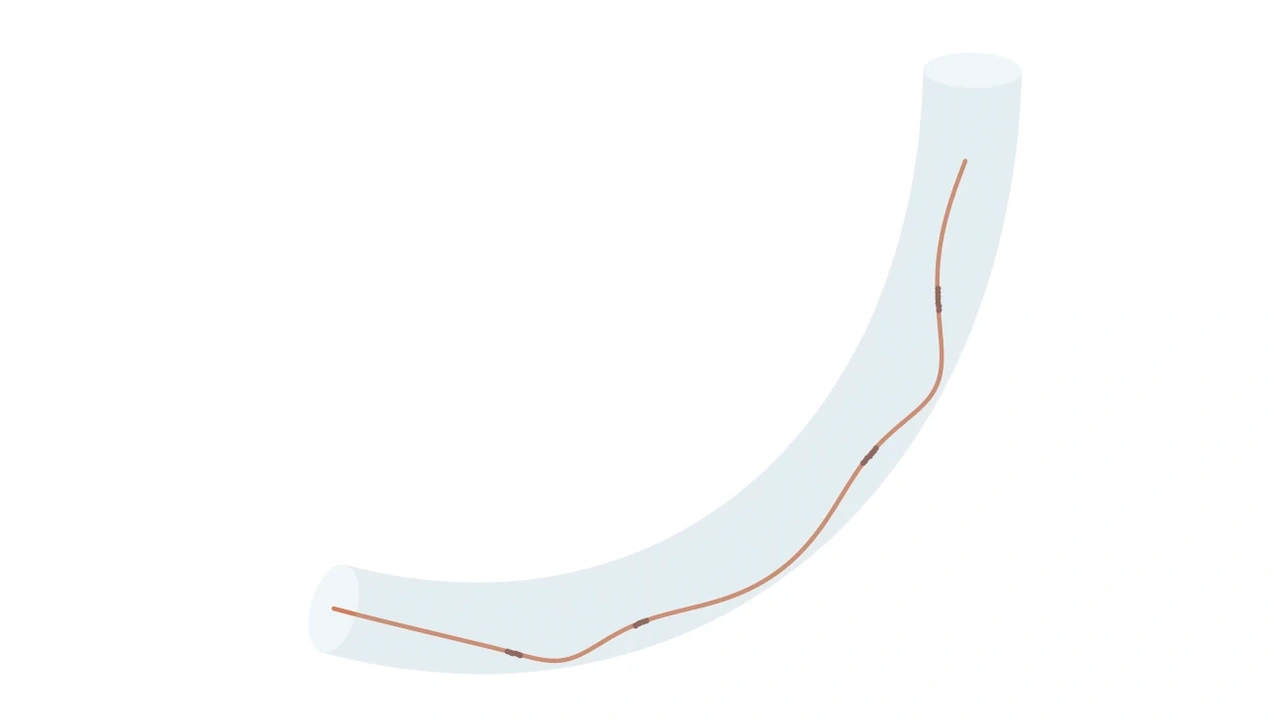
Guidewire Dynamics & Vascular Contact Modeling
A 3D discrete-elastic-rod simulator with analytic and mesh vessel contact, a verified C++/Eigen mechanics backend, and a planar Coulomb-friction guidewire-insertion benchmark.
- Discrete Elastic Rods
- Contact Mechanics
- Numerical Simulation
- C++
- Eigen
- PyTorch
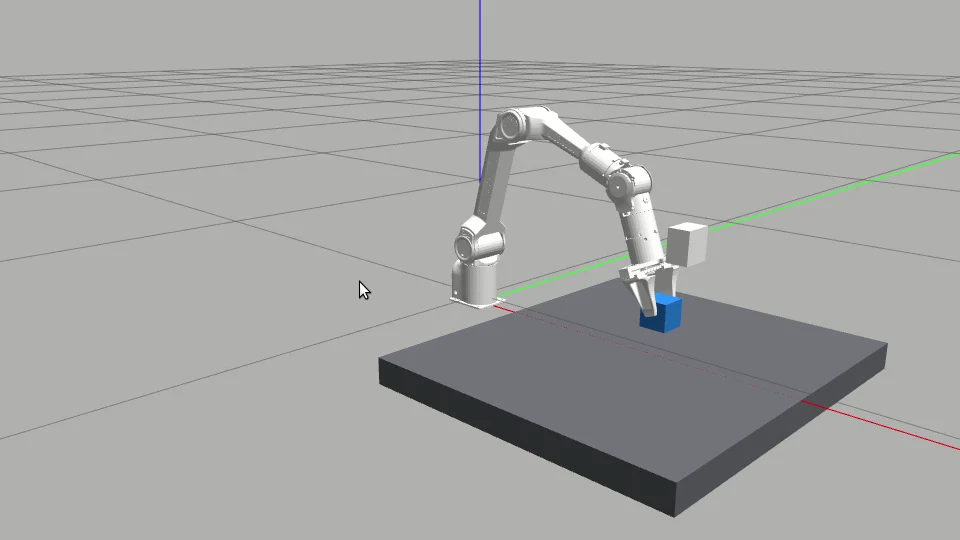
Closed-Loop Visual Tracking and Robotic Grasping
A Piper eye-in-hand RGB-D manipulation system that connects semantic perception to planning and grasp execution, with a controlled study of target-pose commitment.
- ROS 2
- RGB-D Perception
- MoveIt 2
- Gazebo
- Closed-Loop Tracking
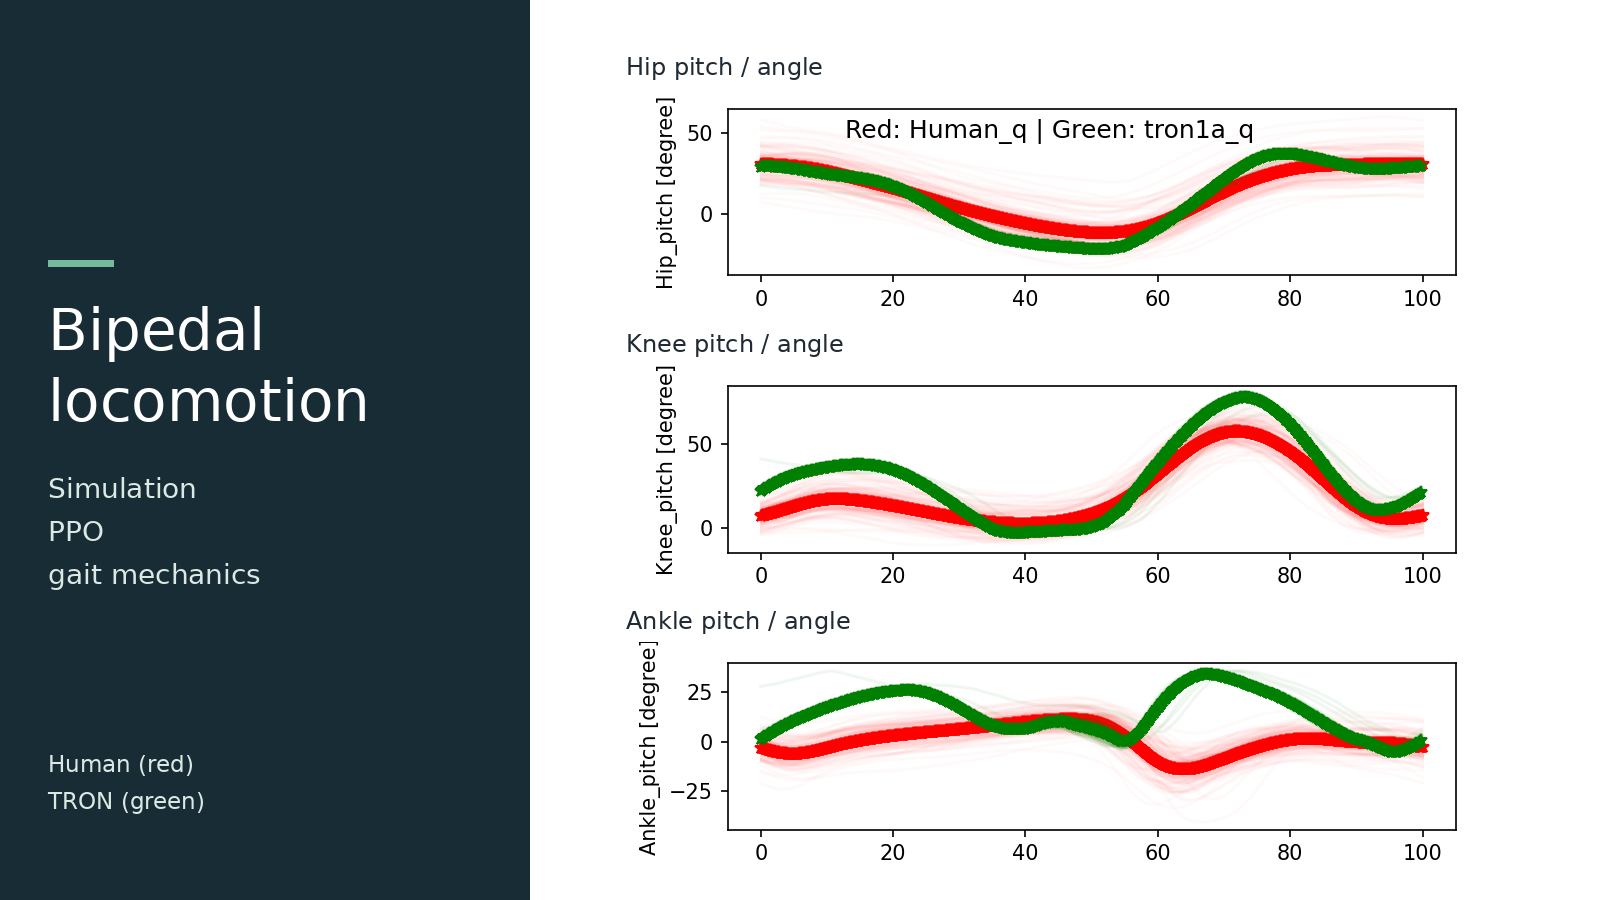
Energy-Efficient Bipedal Locomotion
Independent 2D simulation development, 3D PPO training in the lab’s framework, human–robot gait analysis, and cross-platform evaluation for LIMX TRON 1A.
- Reinforcement Learning
- Dynamics
- Isaac Gym
- MuJoCo
- Bipedal Locomotion
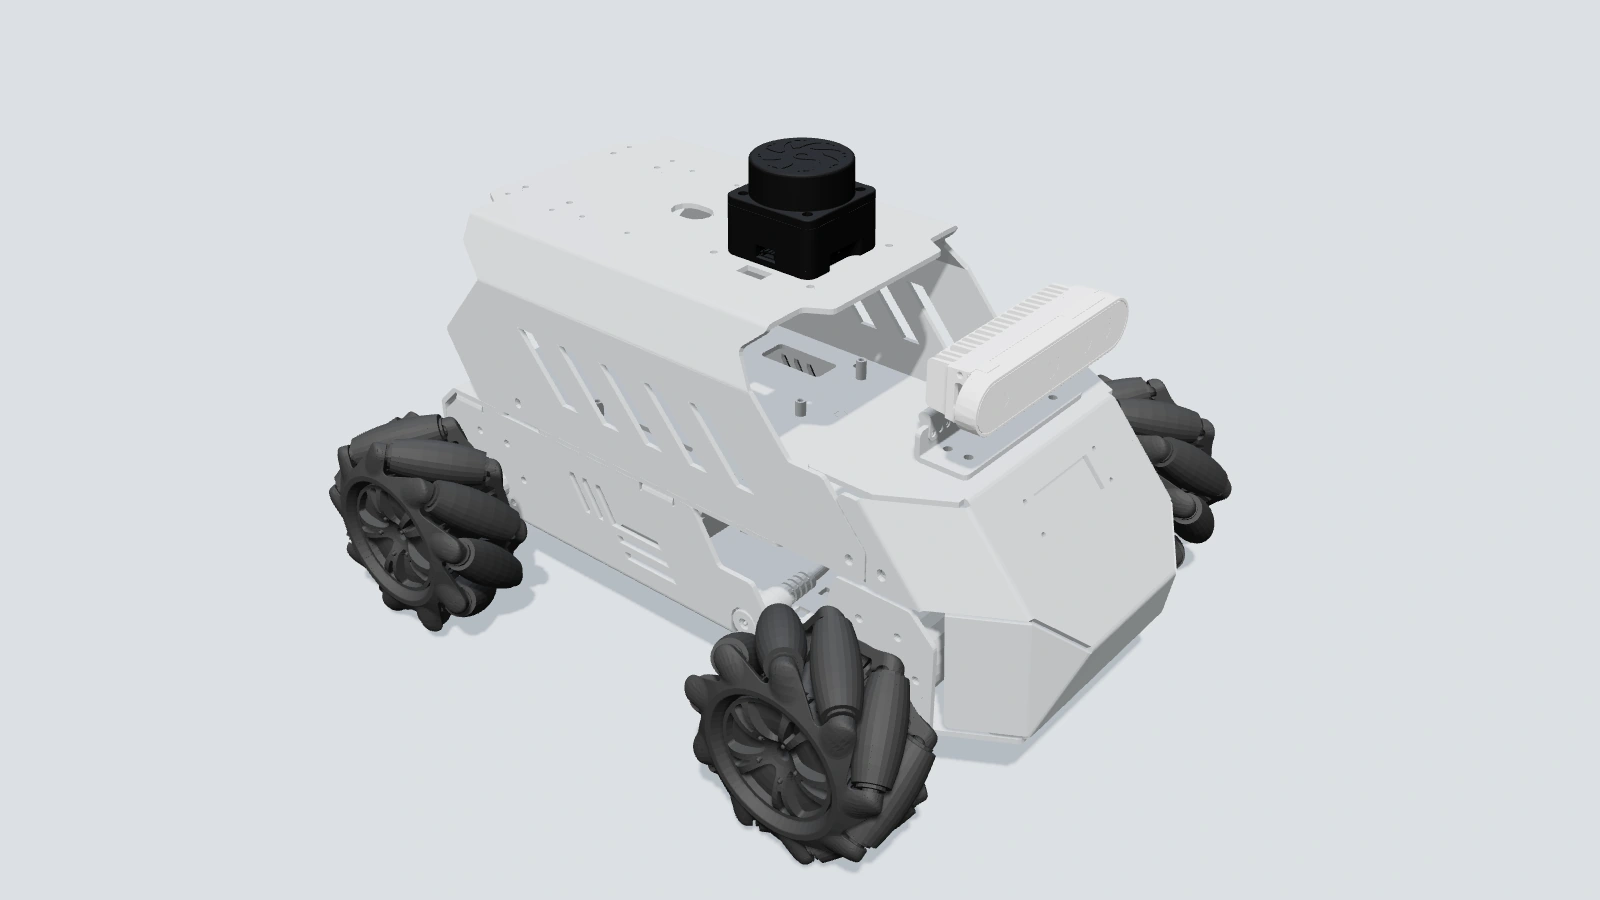
Mobile Robot Navigation & Control
Studied predictive occupancy in an omnidirectional navigation testbed, connecting kinodynamic guidance, MPPI, controlled evaluation, and embedded motion control.
- Dynamic Navigation
- Predictive Occupancy
- MPPI
- Embedded Control
02
Engineering
2 projects
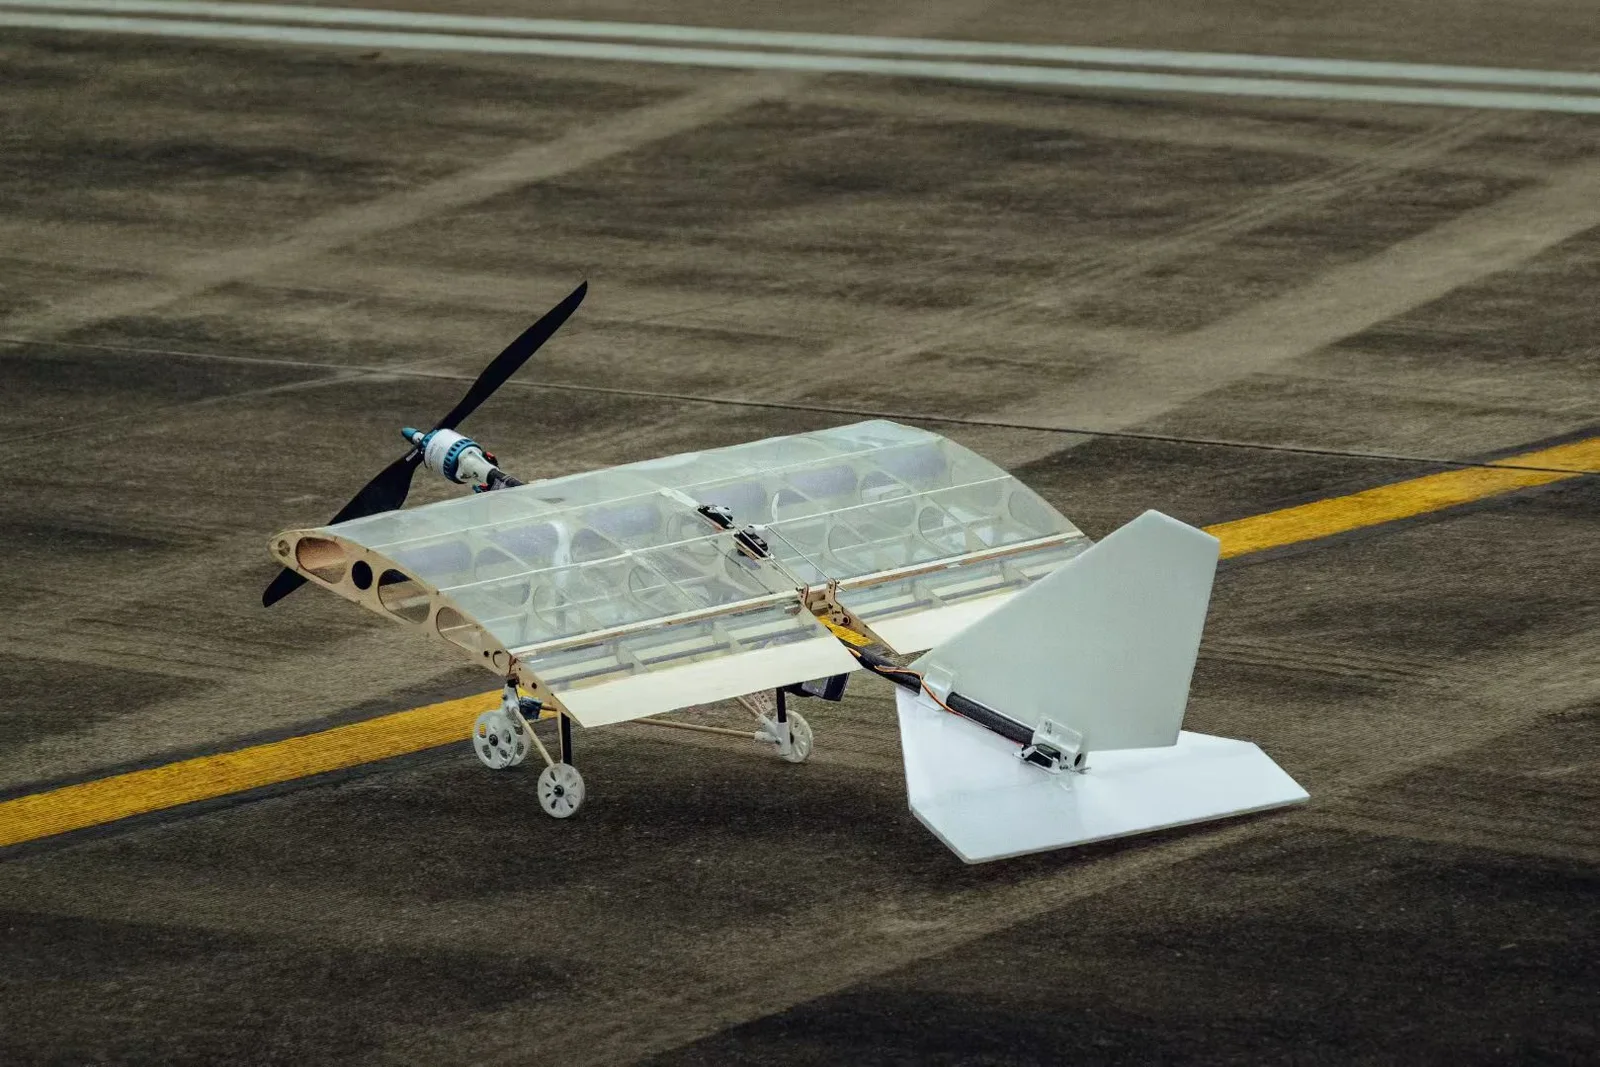
STOL UAV Design & Flight Testing – National First Prize, CUADC
A 770 mm-span, 905 g aircraft that carried a 2.845 kg competition payload and completed a 2.4 m short takeoff.
- Aircraft Design
- Aerodynamics
- Structures
- SolidWorks
- Flight Testing
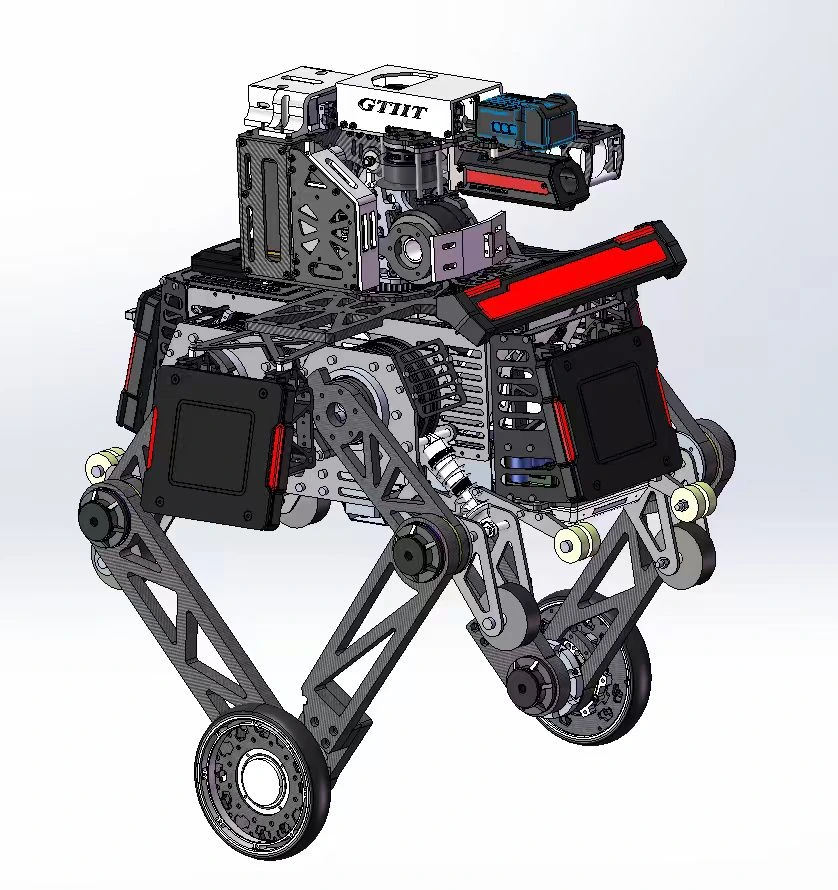
RoboMaster Wheel-Legged Robot – Dynamics & Control
RoboMaster KongFu Team, GTIIT · Electrical Control Group
Electrical-control and control-algorithm development in KongFu Team, with selected work on wheel-legged dynamics, five-bar VMC, gain-scheduled LQR, and nonlinear MATLAB/C validation.
- Embedded Control
- LQR
- Virtual Model Control
- Robot Dynamics