Dynamics and control
Model-based control, MPC, state-space methods, and actuator-aware robot dynamics.
Research portfolio
I am an undergraduate researcher working on robot dynamics, control, and learning. My work spans model predictive control, closed-loop manipulation, reinforcement-learning locomotion, physics-based simulation of flexible robots, and ROS 2 navigation and control systems. I care about explicit assumptions, reproducible experiments, and the gap between methods that work in simulation and systems that work on hardware.
Focus
Model-based control, MPC, state-space methods, and actuator-aware robot dynamics.
Learned dynamics, reinforcement learning, predictive planning, perception, and sim-to-real evaluation.
Manipulation, contact mechanics, flexible robots, and physics-based numerical simulation.
Work
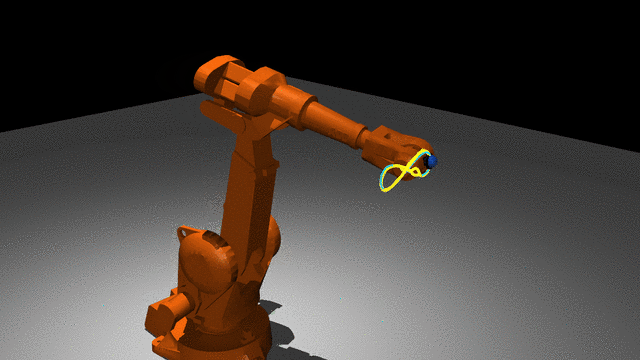
An actuator-aware residual MPC system evaluated in ABB and UR5e MuJoCo simulations and, under a separate hardware protocol, on SO-ARM101.
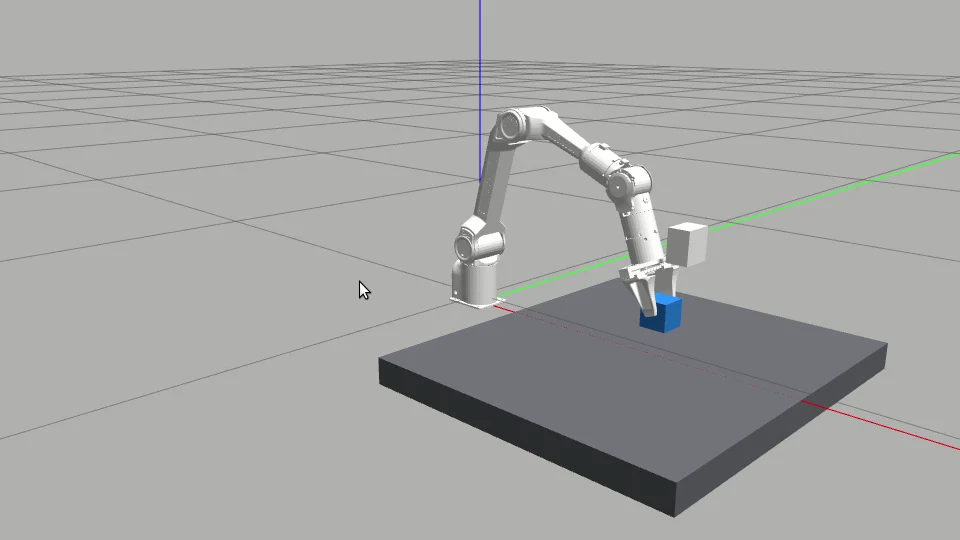
A Piper eye-in-hand RGB-D manipulation system that connects semantic perception to planning and grasp execution, with a controlled study of target-pose commitment.
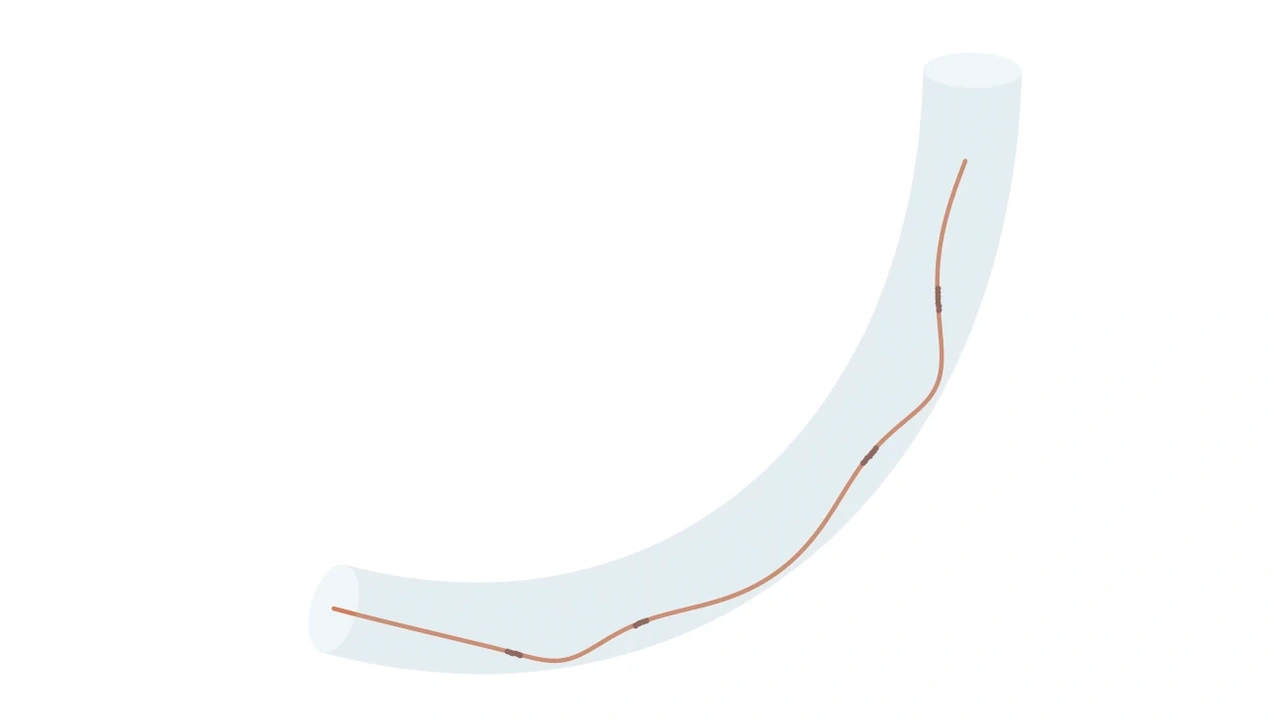
A 3D discrete-elastic-rod simulator with analytic and mesh vessel contact, a verified C++/Eigen mechanics backend, and a planar Coulomb-friction guidewire-insertion benchmark.
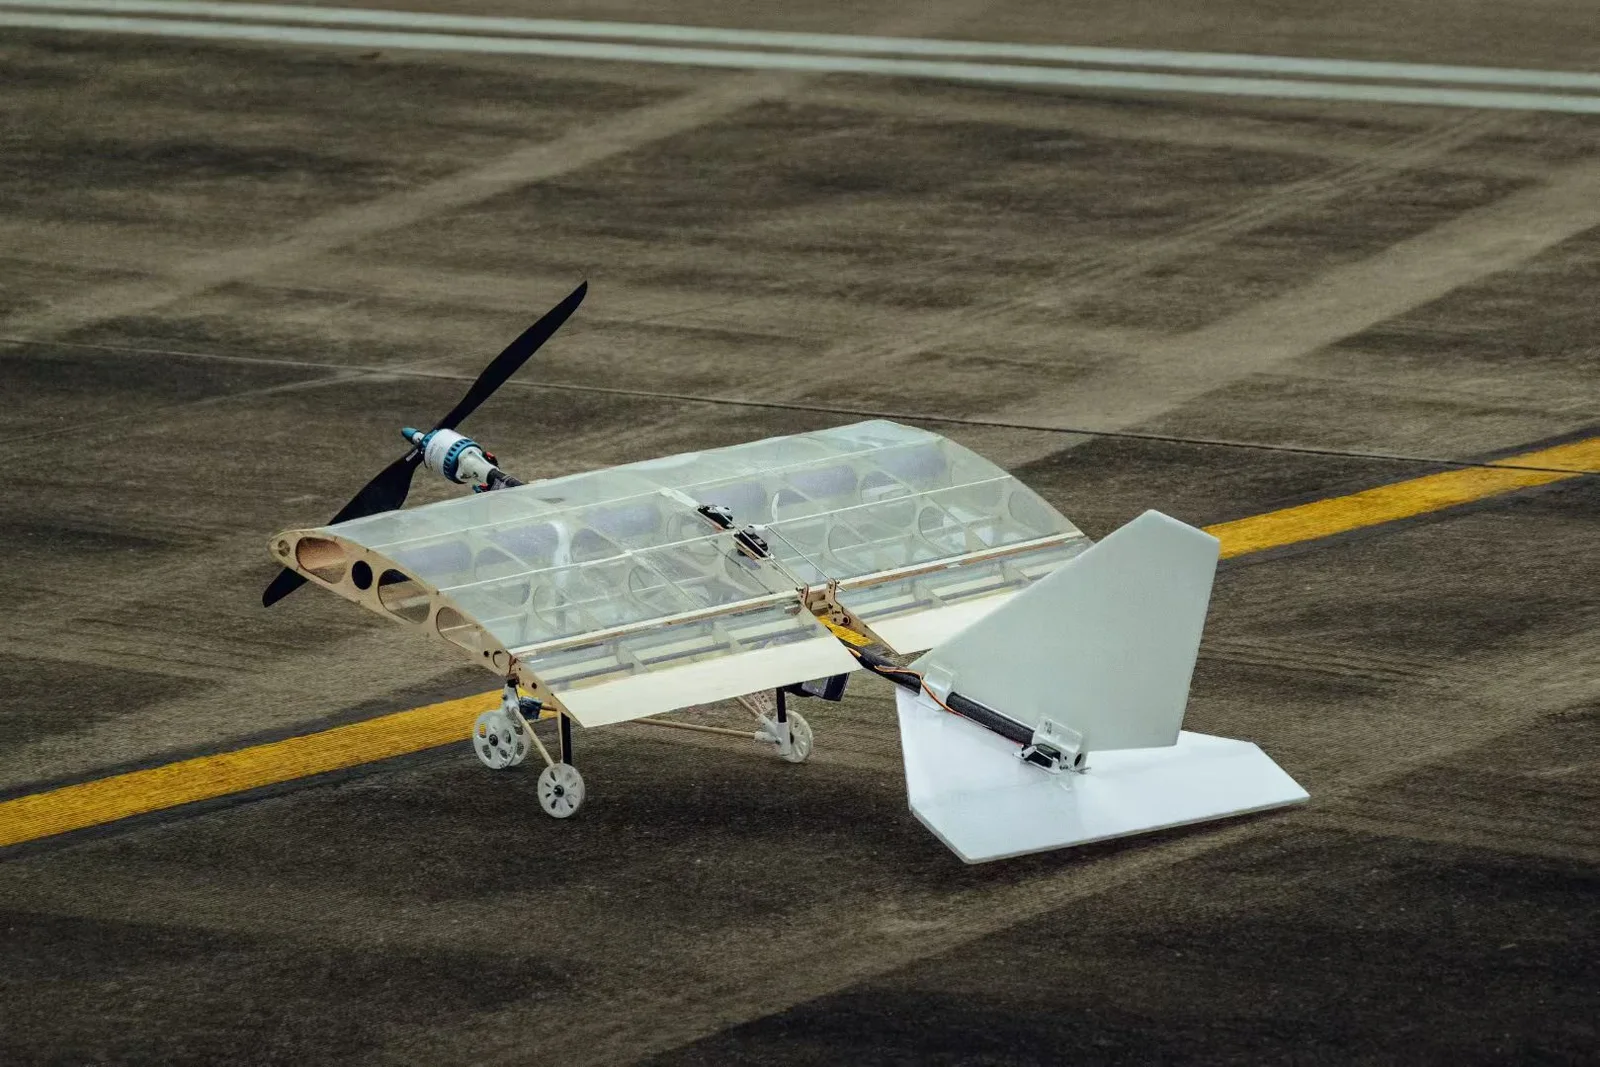
A 770 mm-span, 905 g aircraft that carried a 2.845 kg competition payload and completed a 2.4 m short takeoff.
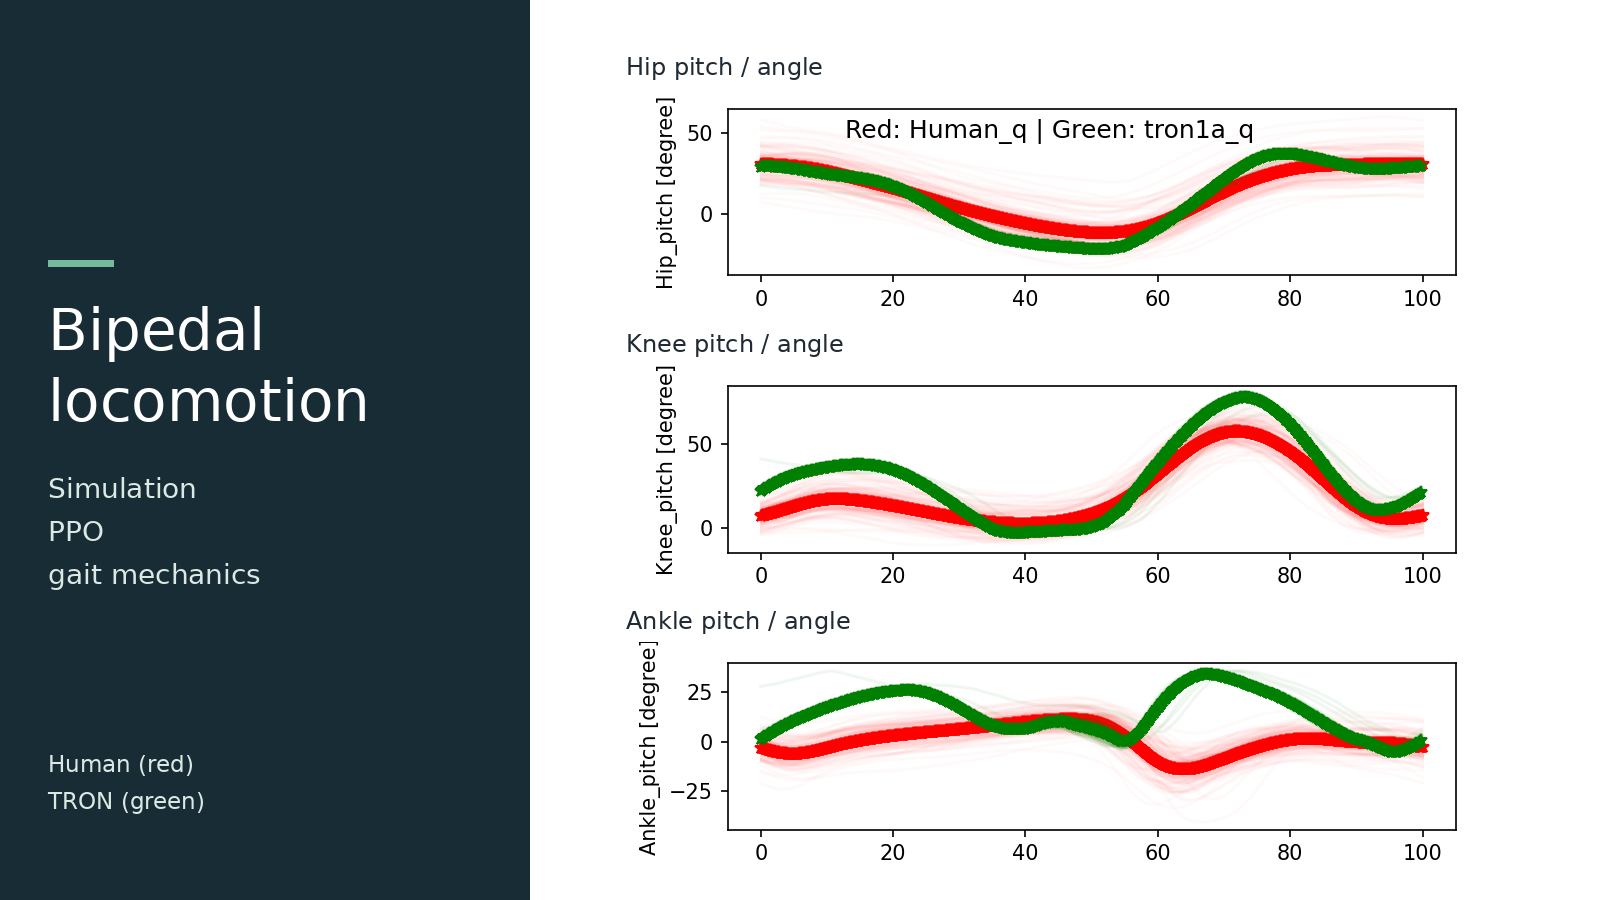
Independent 2D simulation development, 3D PPO training in the lab’s framework, human–robot gait analysis, and cross-platform evaluation for LIMX TRON 1A.
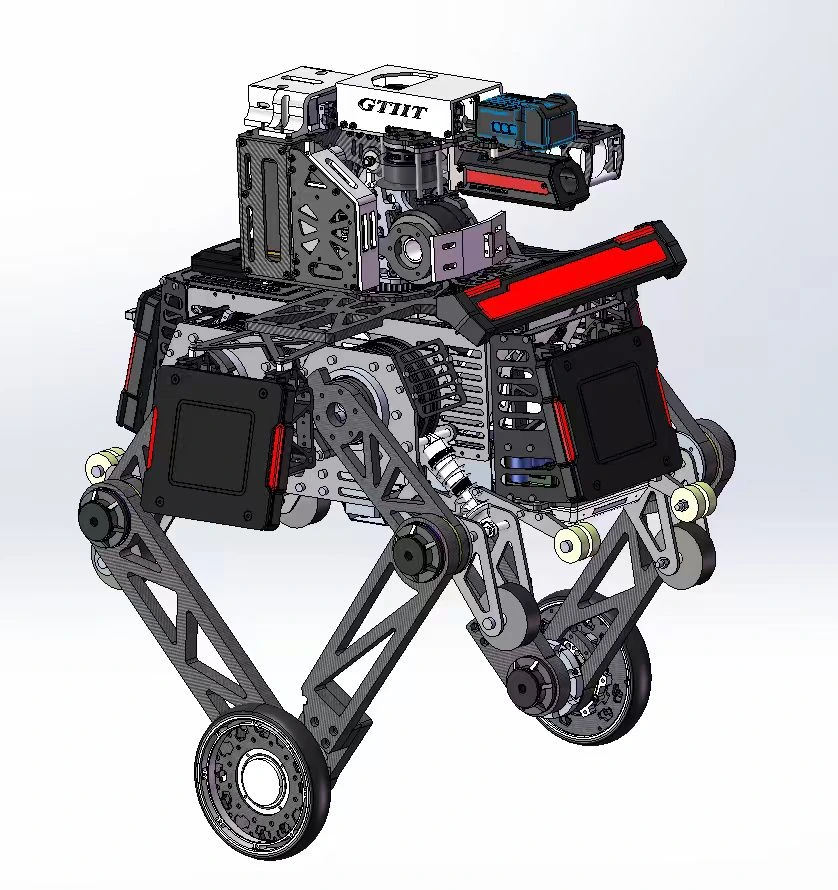
RoboMaster KongFu Team, GTIIT · Electrical Control Group
Electrical-control and control-algorithm development in KongFu Team, with selected work on wheel-legged dynamics, five-bar VMC, gain-scheduled LQR, and nonlinear MATLAB/C validation.
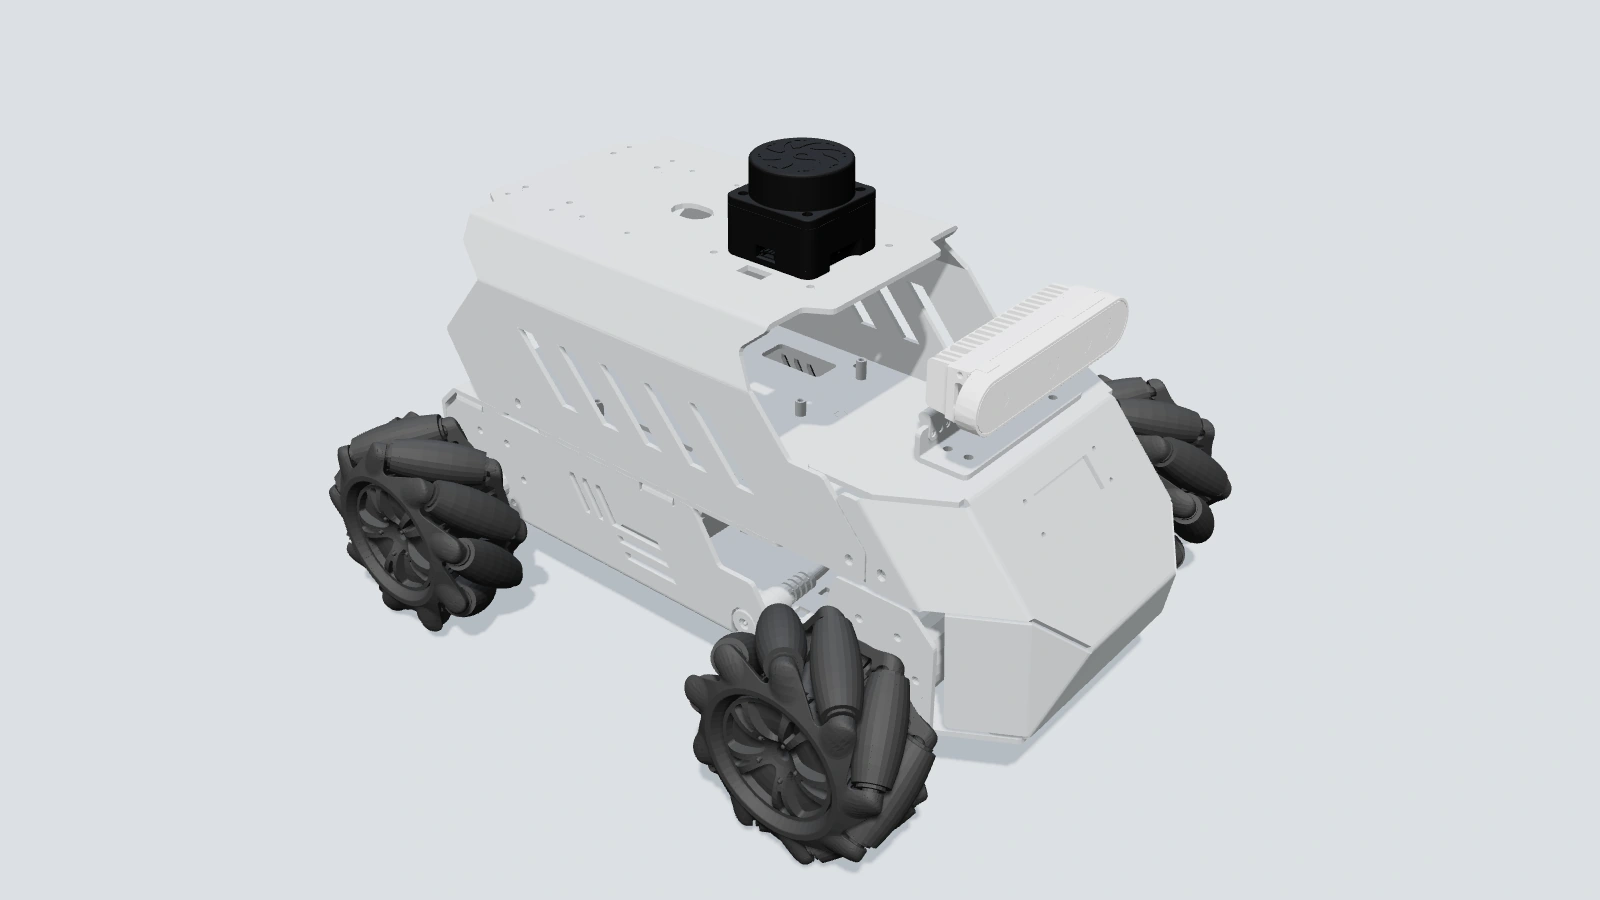
Studied predictive occupancy in an omnidirectional navigation testbed, connecting kinodynamic guidance, MPPI, controlled evaluation, and embedded motion control.
Experience
Jul. – Dec. 2025
Prof. Mingyi Liu
Trained PPO locomotion policies for the LIMX TRON 1A in Isaac Gym and analyzed gait cycles, mechanical cost of transport, and cross-simulator behavior.
Apr. 2026 – Aug. 2026
Prof. Zhujiang Wang
Co-developed a three-dimensional discrete elastic rod simulator with implicit Euler and Newton solves, analytic and mesh contact, and a C++/Eigen backend.
Sep. 2026 – Present
Prof. Mingyi Liu
Built a ROS 2/Gazebo navigation testbed integrating kinodynamic local guidance, predictive occupancy, reproducible simulation evaluation, and embedded motion-control firmware.
Writing
Under Review · IEEE ROBIO 2026
Xinlei Lin, Chenyu Lin, Yue Zhang
Under Review · IEEE EPIC 2026
Yue Zhang and Xinlei Lin
Personal
Photography is one of the ways I slow down and pay attention to places, light, and everyday details.
Toolkit
Programming Python · C/C++ · MATLAB
Robotics ROS 2 · Nav2 · MoveIt 2 · Gazebo · MuJoCo · Isaac Gym
Control & Learning MPC · MPPI · LQR · VMC · PPO · PyTorch
Numerical & Systems Eigen · NumPy · CMake · Git · Linux
Embedded & Design STM32 · FreeRTOS · SolidWorks
Contact
I am happy to discuss research, engineering work, or graduate study opportunities.
lin24872@gtiit.edu.cn

